
What is Seed GR-3
Seed GR-3 is a general-purpose robot model launched by the ByteDance Seed team, with high generalization capability, long-horizon task handling capability, and deformable object manipulation capability. Seed GR-3 integrates a "brain" that fuses vision-language-action information, a three-in-one data training method (robot data, VR human trajectory data, and public image-text data), and a customized flexible "body" ByteMini, enabling understanding and execution of new objects, new environments, and complex instructions. GR-3 performs outstandingly in long-sequence tasks, dual-arm collaborative manipulation, and deformable object manipulation, and is an important step toward a general-purpose robot "brain".
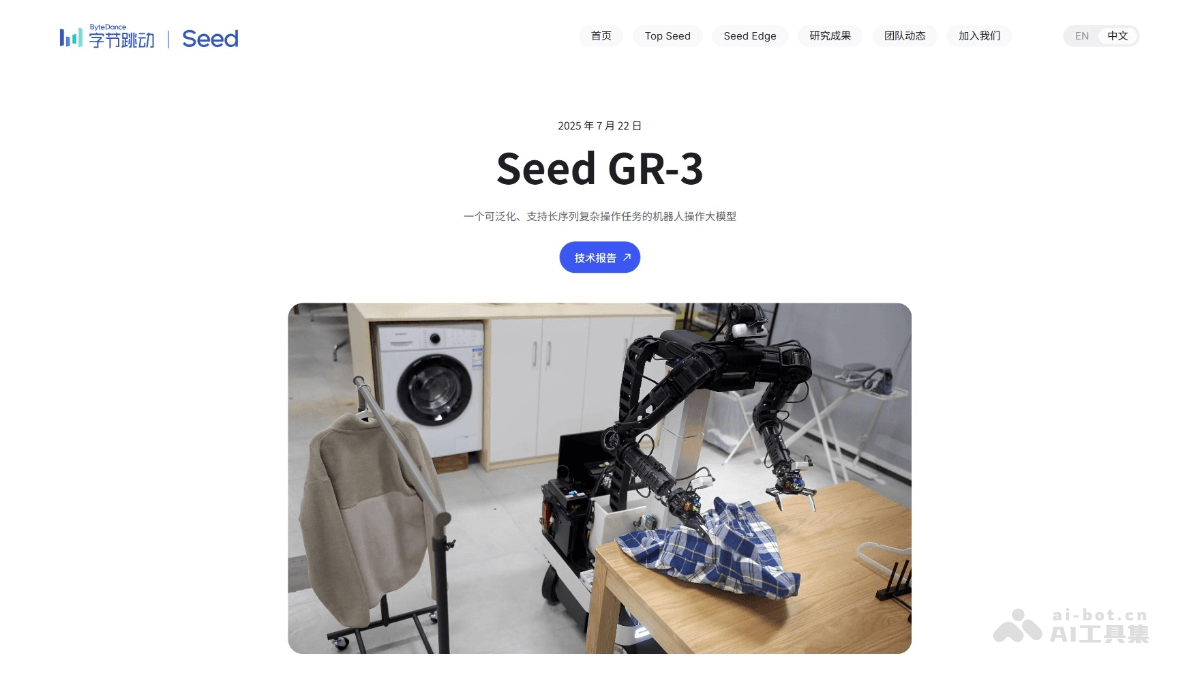
Main features of Seed GR-3
- High generalization capability: Can adapt to new objects, new environments, and complex instructions containing abstract concepts.
- Long-horizon task handling: Supports efficient completion of multi-step tasks, such as complex household chores like clearing a dining table.
- Deformable object manipulation: Supports fine manipulation of deformable objects, such as hanging clothes, and can handle unseen clothing types.
- Fast fine-tuning: Efficiently fine-tunes based on a small amount of human trajectory data, quickly adapting to new tasks.
- Dual-arm collaborative manipulation: Supports two-handed collaborative tasks, such as completing complex actions with both hands working together.
- Whole-body manipulation capability: Combines chassis movement to achieve whole-body manipulation and adapt to more scenarios.
Technical principles of Seed GR-3
- Fused brain: Uses a Mixture-of-Transformers (MoT) network architecture to combine the vision-language module and the action generation module, forming a 4-billion-parameter end-to-end model. The action generation module uses a Diffusion Transformer (DiT) to generate actions based on Flow-Matching.
- Three-in-one data training method:
- Robot data: Collects high-quality robot action trajectories based on teleoperation.
- VR human trajectory data: Uses VR devices to collect human manipulation trajectories, improving learning efficiency.
- Public image-text data: Uses large-scale vision-language data to improve the model's understanding of new objects and abstract concepts.
- Customized body: Paired with the ByteMini robot, it has 22 degrees of freedom, supports highly flexible manipulation, and is suitable for confined spaces and fine tasks.
Seed GR-3 project address
- Project official website:https://seed.bytedance.com/zh/GR3
- arXiv technical paper:https://arxiv.org/pdf/2507.15493
Application scenarios of Seed GR-3
- Home services: The model can assist with household chores, care for the elderly and children, and ensure safety, making family life easier.
- Industrial logistics: Seed GR-3 can optimize warehouse management, assist production, and inspect quality, improving industrial efficiency.
- Healthcare: Helps with patient rehabilitation, assists in surgery, and manages logistics, improving healthcare services.
- Retail services: Seed GR-3 can organize shelves, serve customers, and guide exhibitions, optimizing the retail experience.
- Disaster rescue: The model can participate in rescue operations and monitor environments, providing support for emergency response.