
What is Kairos 3.0-4B
Kairos 3.0-4B is Daxiao Robotics' open-source embodied native world model, pioneering a "multimodal understanding—generation—prediction" integrated architecture. As the world's first 4B lightweight model capable of on-device driving robot body control, it achieves 1:1.5 real-time generation on the THOR platform, with inference speed 72 times faster than Cosmos 2.5. The model possesses ultimate physical causal consistency, can generate 7-minute long-duration coherent interactive videos, and supports cross-embodiment generalization, enabling the same "brain" to drive multiple robot forms, providing a core engine for the large-scale deployment of embodied intelligence.
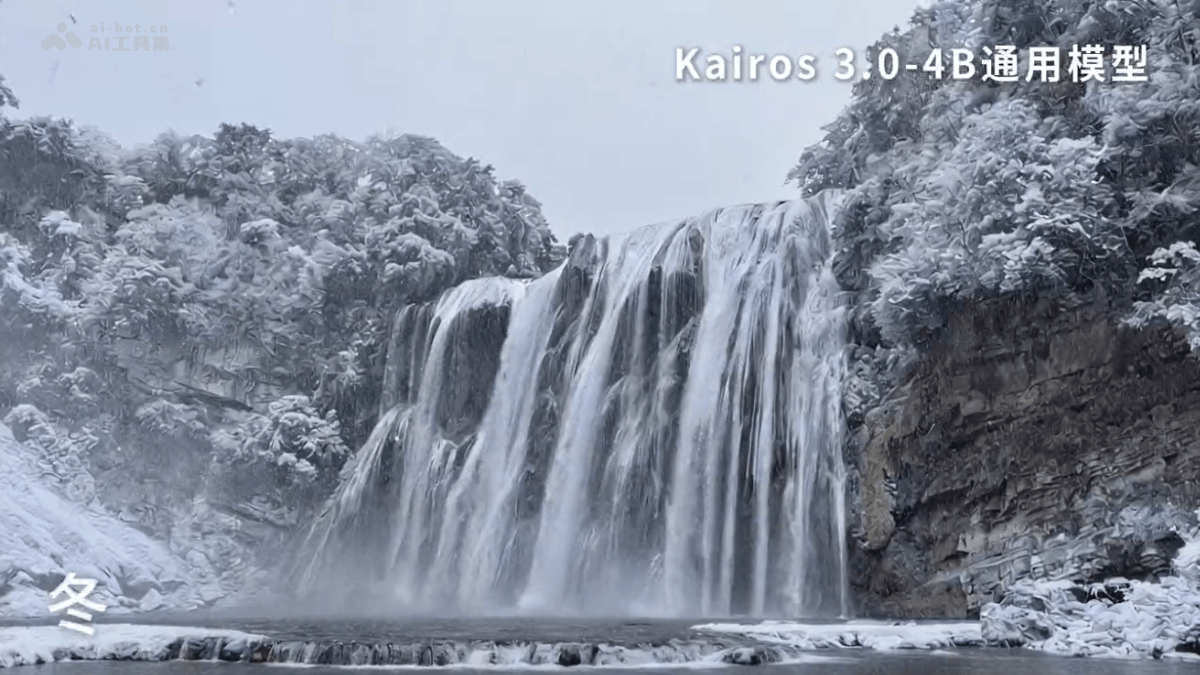
Main Features of Kairos 3.0-4B
-
Physical-level world understanding and generation: Accurately reproduces real physical effects such as natural light and shadow, fluid dynamics, and rigid body mechanics. When pouring water, the total liquid volume is conserved; when stacking stones, gravity and support laws are followed.
-
Long-duration dynamic interaction: Can generate 7-minute coherent interactive videos, and combined with Agent intelligence, enables complete household task workflows such as organizing a desk, doing laundry, and making breakfast.
-
Robot body control: The model can directly output comprehensive control commands from the robot's upper limbs and fingers to the lower limbs, achieving real-time response of "what you think is what you do" on an on-device platform.
-
Cross-embodiment generalization: Supports multi-form robots such as single-arm, dual-arm, and dexterous hands, and can adapt to mainstream hardware such as AgiBot, Songling, and Unitree without additional training.
-
Efficient data simulation: As a low-cost data simulator, it scales up training data on a large scale, solving the industry pain point of scarce real-machine interaction data.
Technical Principles of Kairos 3.0-4B
- Native embodied architecture: Unlike "retrofit" solutions that attach motion interfaces to large models, Kairos is designed from the architectural foundation for real-world robot operation, taking the physical laws and causal laws of nature as its cognitive foundation, achieving a leap from "behavior imitation" to "physical-level deep understanding".
- Multimodal integrated framework: Integrates the three major capabilities of "understanding—generation—prediction", embedding physical laws and causal chains of thought into the model's decision-making process. It is compatible with vision, text, and sensor instructions, and accurately parses physical constraints such as object forces, center of gravity, and friction.
- Triple data fusion: Deeply integrates three types of data: real robot interaction, structured human behavior, and chain-of-thought text, breaking down data barriers and achieving strong generalization and reliable deployment under better model and data scales.
- Agent intelligence technology: Through hierarchical instruction parsing and structured decomposition, it finely predicts spatiotemporal evolution and interaction logic, and relies on a self-reflection mechanism to achieve closed-loop iterative optimization, completing continuous world information.
- Efficient inference operators: Self-developed hybrid temporal linear attention operators achieve inference speeds 72 times faster than mainstream models with 4B lightweight parameters, enabling real-time on-device generation while maintaining extremely low memory usage.
Kairos 3.0-4B Project Address
- GitHub Repository:https://github.com/kairos-agi/kairos-sensenova
- HuggingFace Model Library:https://huggingface.co/kairos-agi/kairos-sensenova-common
Application Scenarios of Kairos 3.0-4B
- Industrial manufacturing: Used for simulation training and trajectory planning of long-process assembly tasks, previewing complex operations in a virtual environment to reduce real-machine debugging costs and risks.
- Home services: Driving robots to complete daily household chores such as tidying and organizing, laundry and cooking, and item delivery, with a 7-minute long-duration interaction capability that supports continuous service scenarios.
- Logistics and Warehousing: Enabling dynamic planning and real-time control for tasks such as cargo handling, sorting and palletizing, and shelf inspection, adaptable to robotic arms and mobile robots of different forms.
- Commercial Services: The model can support scenarios such as guided reception, food and beverage delivery, and cleaning and maintenance, and its cross-embodiment generalization capability allows the same system to quickly adapt to robot hardware in different stores.
- Data Collection and Synthesis: As an efficient data simulator, it generates physically consistent training data at low cost and scale, alleviating the bottleneck of scarce real-machine interaction data.