
What is InternVLA-A1
InternVLA-A1 is an embodied manipulation large model jointly released by Shanghai Artificial Intelligence Laboratory and the National and Local Joint Humanoid Robot Innovation Center. It has the integrated capabilities of understanding, imagination, and execution, and can accurately complete tasks. The model integrates real and simulated manipulation data, and through large-scale virtual-real hybrid scene assets, automatically constructs massive multimodal corpora, with a data scale reaching 6 million entries. Its "one brain, multiple forms" feature enables it to support multiple robot bodies and achieve zero-shot generalization across scenarios and bodies. InternVLA-A1 performs excellently in highly dynamic scenarios, has strong adaptability, and can achieve stable dynamic interaction. Its performance is significantly better than other similar models in real-machine evaluations. InternVLA-A1 has been open-sourced, providing researchers and developers with rich data resources and helping the development of humanoid robot technology.
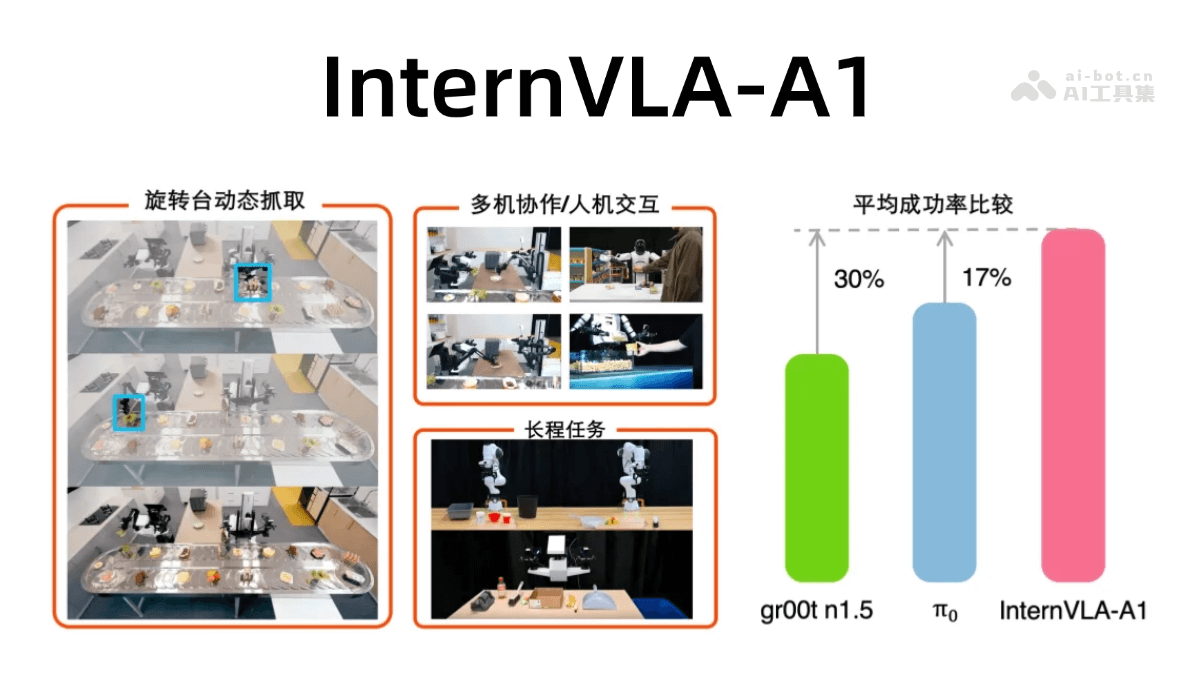
Main Features of InternVLA-A1
-
Understanding and Imagination: It can accurately understand scenes and task requirements, and through imagination plan reasonable operation paths and steps, providing a clear blueprint for subsequent execution.
-
Precise Execution: On the basis of understanding, the model can precisely control robots to complete various manipulation tasks, such as grasping, transporting, and assembling, ensuring accurate task completion.
-
Virtual-Real Integration: It integrates real and simulated manipulation data and constructs large-scale virtual-real hybrid scene assets, enabling the model to perform excellently in both virtual and real scenarios and enhancing its generalization ability and adaptability.
-
Multi-Robot Collaboration: It supports collaboration among multiple robots, can reasonably allocate tasks according to task requirements, and achieves efficient collaborative work, making it suitable for multi-robot manipulation tasks in complex scenarios.
-
Cross-Platform Adaptation: It has the "one brain, multiple forms" feature and can adapt to multiple robot bodies, such as Fangzhou Infinite, Guodi Qinglong humanoid robot, Zhiyuan Genie, etc., with good compatibility and versatility.
-
Dynamic Interaction: It performs excellently in highly dynamic scenarios, can perceive environmental changes in real time and respond quickly, achieving stable dynamic interaction and adapting to complex and ever-changing real-world scenarios.
Technical Principles of InternVLA-A1
-
Multimodal Data Fusion: It integrates multiple data types such as real-world data, simulation data, and text descriptions, constructing a large-scale multimodal dataset and providing rich corpus support for model training.
-
Virtual-Real Hybrid Training: Through a virtual-real hybrid dataset, combining simulated data in virtual environments and collected data in real scenarios, the model can effectively learn and optimize in both virtual and real environments, improving its generalization ability.
-
Self-Supervised Learning: By using self-supervised learning methods, the model can automatically learn the intrinsic structure and features of data even without labeled data, improving the model's understanding and adaptability to complex scenarios.
-
Reinforcement Learning Optimization: It adopts reinforcement learning algorithms to optimize the model's behavioral strategies through interaction with the environment, enabling the model to continuously learn and improve in actual operations to achieve better execution results.
-
Cross-Modal Understanding and Generation: The model can achieve cross-modal understanding and generation from vision and language to actions, effectively fusing and converting information from different modalities, better understanding task requirements, and generating corresponding operation instructions.
-
Dynamic Adaptation and Interaction: It possesses dynamic adaptation capabilities, can perceive environmental changes in real time and respond quickly, achieving stable interaction with the environment, especially performing excellently in highly dynamic scenarios, ensuring the smooth execution of tasks.
InternVLA-A1 project address
- Github repository:https://github.com/InternRobotics/InternVLA-A1
- HuggingFace data address:https://huggingface.co/datasets/InternRobotics/InternData-A1
Application scenarios of InternVLA-A1
-
Home services: It can assist with household chores, such as organizing items, cleaning, and caring for the elderly and children, improving the convenience and comfort of home life.
-
Industrial manufacturing: It can be used for parts assembly, material handling, quality inspection, and other work on production lines, improving production efficiency and product quality.
-
Logistics and warehousing: In logistics centers and warehouses, it performs tasks such as cargo sorting, handling, and stacking, optimizing logistics processes and reducing labor costs.
-
Medical care: It assists medical staff with patient care, such as helping patients with rehabilitation training and moving medical equipment, reducing the workload of medical staff.
-
Public services: In public places such as airports, stations, and shopping malls, it provides information consultation, guidance services, cleaning and maintenance, etc., improving the quality and efficiency of public services.
-
Education and scientific research: As a scientific research tool, it helps researchers conduct experimental operations and data collection; in the field of education, as a teaching assistant, it supports teaching activities and stimulates students' interest in learning.