
What is InteriorGS
InteriorGS is a high-quality 3D Gaussian semantic dataset launched by Qunhe Technology, containing 1000 3D Gaussian semantic scenes and covering more than 80 types of indoor environments, such as homes, convenience stores, wedding banquet halls, and museums. The dataset contains more than 554,000 object instances across 755 categories, and each object has a 3D box and semantic annotation, providing occupancy maps to support navigation and spatial understanding. InteriorGS is the world's first large-scale 3D dataset suitable for free movement of agents, using 3D Gaussian splatting technology to reconstruct scenes and combining spatial large models to assign semantic information. It provides abundant training material for improving the spatial perception capabilities of robots and AI agents, and has been made public on HuggingFace and Github for developers worldwide to use.
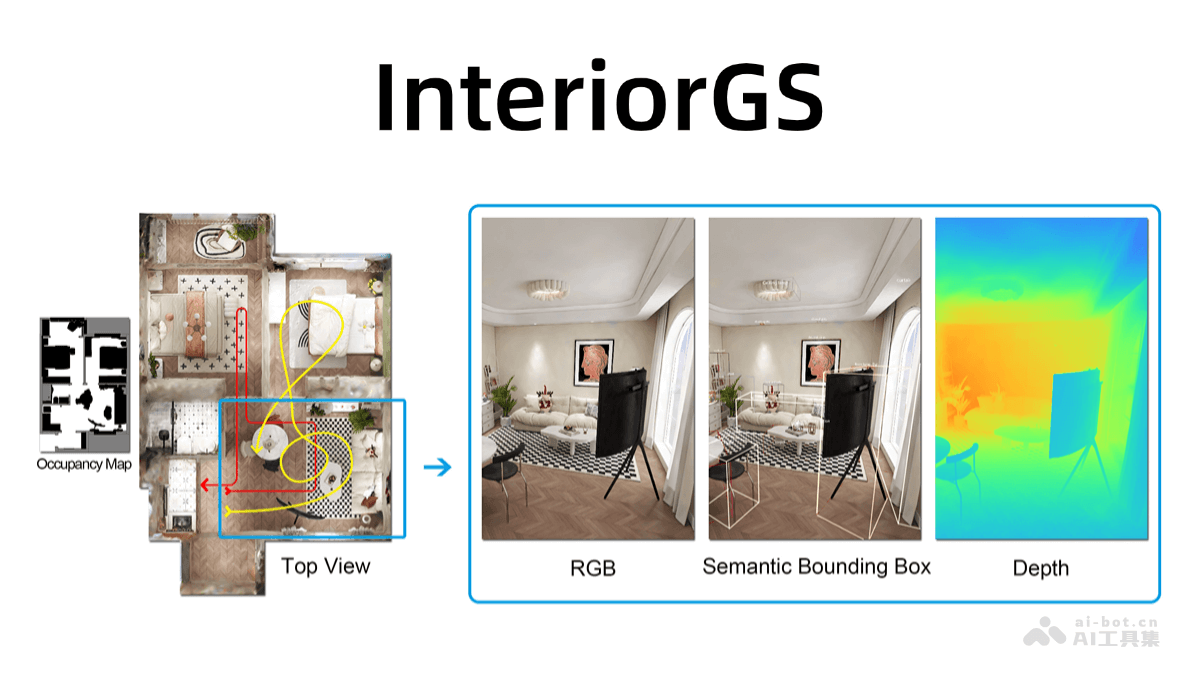
Main features of InteriorGS
-
Diverse scenes: Contains 1000 3D scenes, covering more than 80 types of indoor environments such as homes, convenience stores, wedding banquet halls, and museums.
-
High-density object annotations: Each scene contains more than 554,000 object instances across 755 categories, and each object is annotated with a 3D box and semantic information.
-
Occupancy maps: Each scene provides an occupancy map, helping agents understand the spatial layout and supporting path planning and obstacle avoidance.
-
Dynamic environment adaptation: The dataset supports agents moving freely in dynamic environments, improving their adaptability and flexibility.
-
High-quality annotations: Combines 3D Gaussian splatting technology to reconstruct scenes and assign semantic information, providing high-quality training data for AI models.
-
Large-scale dataset: As the world's first large-scale 3D dataset suitable for free movement of agents, it provides abundant material for model training.
InteriorGS project address
- Github repository:https://github.com/manycore-research/InteriorGS
- HuggingFace model library:https://huggingface.co/datasets/spatialverse/InteriorGS
Application scenarios of InteriorGS
-
Indoor navigation: Robots can perform autonomous navigation in complex indoor environments such as homes, offices, and shopping malls. The high-precision 3D scenes and occupancy maps provided by InteriorGS can help robots perceive the environment in real time, plan optimal paths, and avoid obstacles.
-
Spatial perception: The 3D scenes and occupancy maps in the dataset help train the spatial perception capabilities of AI models, enabling them to better understand the layout and structure of indoor spaces.
- Virtual environment construction: The 3D scenes of InteriorGS can be used to construct virtual environments in virtual reality (VR) and augmented reality (AR) applications.
- Spatial layout optimization: Architects and designers can use the 3D scenes and occupancy maps in InteriorGS to optimize indoor spatial layouts.
-
Smart device deployment: InteriorGS data can help smart home systems better understand indoor environments and deploy smart devices more reasonably, such as smart cameras, sensors, and smart home appliances.