
What is Helix
Helix is a general vision-language-action (VLA) model introduced by Figure for controlling humanoid robots. Helix pioneeringly achieves high-rate (200Hz) continuous control of the robot's entire upper body (including wrists, torso, head, and fingers), supports multi-robot collaboration, with multiple robots sharing the same set of neural network weights to complete tasks. Helix picks up never-before-seen objects based on natural language instructions, demonstrating strong generalization ability. Helix's training is fully end-to-end, requiring no task-specific fine-tuning, runs on low-power GPUs, and has commercial deployment potential.
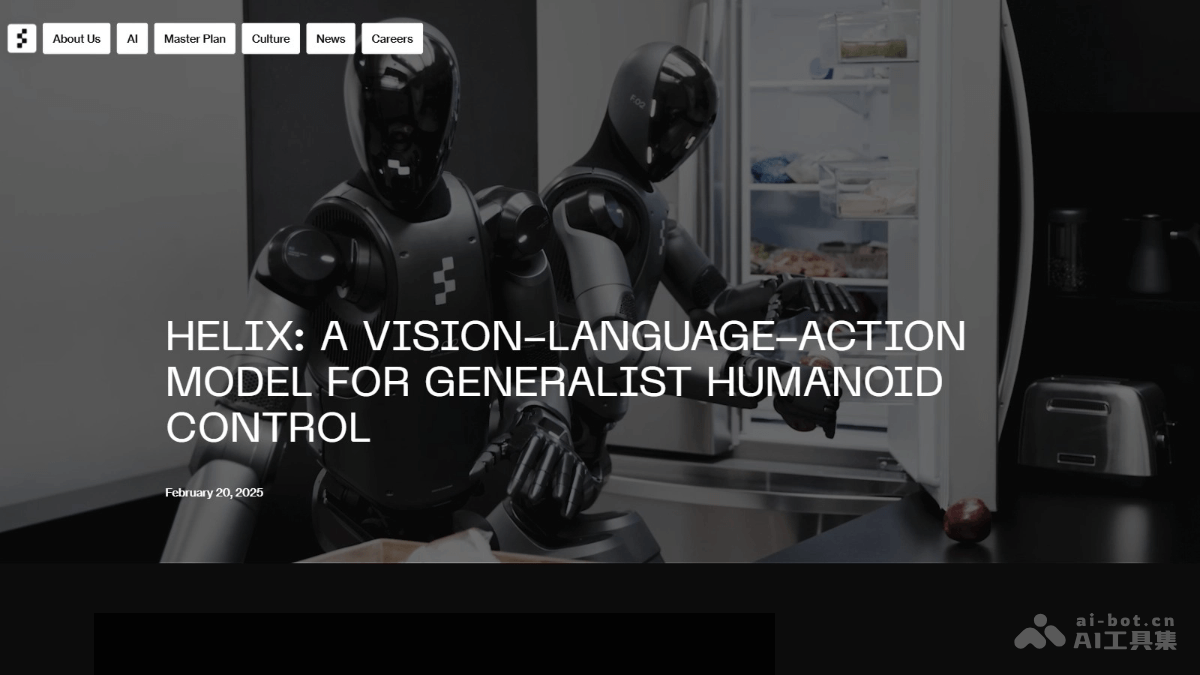
Helix's Main Features
- Full Upper Body Control: High-rate (200Hz) continuous control of the robot's entire upper body (including wrists, torso, head, and fingers), achieving high-precision motion coordination.
- Multi-Robot Collaboration: Supports multiple robots simultaneously running the same set of neural network weights, enabling collaborative task completion, such as jointly carrying or organizing items.
- Natural Language Understanding and Execution: The robot completes various tasks based on natural language instructions, such as picking up never-before-seen objects, operating drawers or refrigerators, etc.
- Strong Generalization Ability: Handles thousands of items with different shapes, sizes, and materials.
- Commercial Deployment Capability: Runs entirely on low-power embedded GPUs, suitable for large-scale commercial applications.
Helix's Technical Principles
- System 2 (S2): Based on a 7B-parameter open-source vision-language model (VLM), responsible for scene understanding and language understanding. It processes at 7-9Hz, used for "slow thinking" of high-level goals, converting visual and language information into semantic representations. It encodes semantic information into continuous latent vectors, which are passed to System 1.
- System 1 (S1): Based on an 80M-parameter Transformer encoder-decoder architecture, used for low-level control. It processes at 200Hz, quickly executing and adjusting actions. It combines the latent vectors passed by S2 with visual features, converting them into precise robot actions (such as wrist posture, finger control, head and torso orientation).
- End-to-End Training: Maps from raw pixels and natural language instructions to continuous action outputs, trained using standard regression loss. Temporal offsets are introduced during training to simulate the inference delays of S1 and S2, ensuring consistency between training and deployment.
- Decoupled Architecture: S1 and S2 operate on different time scales, with S2 responsible for high-level semantic planning and S1 responsible for real-time action execution. This ensures both the system's generalization ability and fast response.
- Optimized Inference Deployment: On the robot, S1 and S2 run on separate GPUs, with S2 asynchronously updating latent vectors and S1 executing action control in real time.
Helix's Project Address
- Project Website:https://www.figure.ai/news/helix
Helix's Technical Principles
- Home Services: Organizing items, storage, operating home appliances, and other daily chores.
- Multi-Robot Collaboration: Multiple robots share one set of neural networks to jointly complete carrying or assembly tasks.
- Object Grasping: Grasping never-before-seen objects based on natural language instructions, suitable for logistics and warehousing.
- Industrial Automation: Used in complex human-robot collaboration tasks, such as component assembly and quality inspection.
- Service industry: Provide guidance, delivery, and cleaning services in places such as hotels and restaurants.