
What is GigaBrain-0
GigaBrain-0 is a novel Vision-Language-Action (VLA) foundation model, driven by data generated from a world model. By generating diverse data at scale, the model reduces its reliance on real robot data and significantly improves cross-task generalization. It adopts RGB-D input modeling to enhance spatial perception, and through Embodied Chain-of-Thought (Embodied CoT) supervision, it strengthens the model's reasoning ability during task execution. This enables GigaBrain-0 to perform excellently in real-world dexterous manipulation, long-horizon tasks, and mobile manipulation tasks. GigaBrain-0 demonstrates excellent generalization ability under scenarios such as changes in appearance, object placement positions, and camera viewpoints. To adapt to edge platforms, a lightweight version, GigaBrain-0-Small, was introduced, enabling efficient operation on devices such as NVIDIA Jetson AGX Orin.
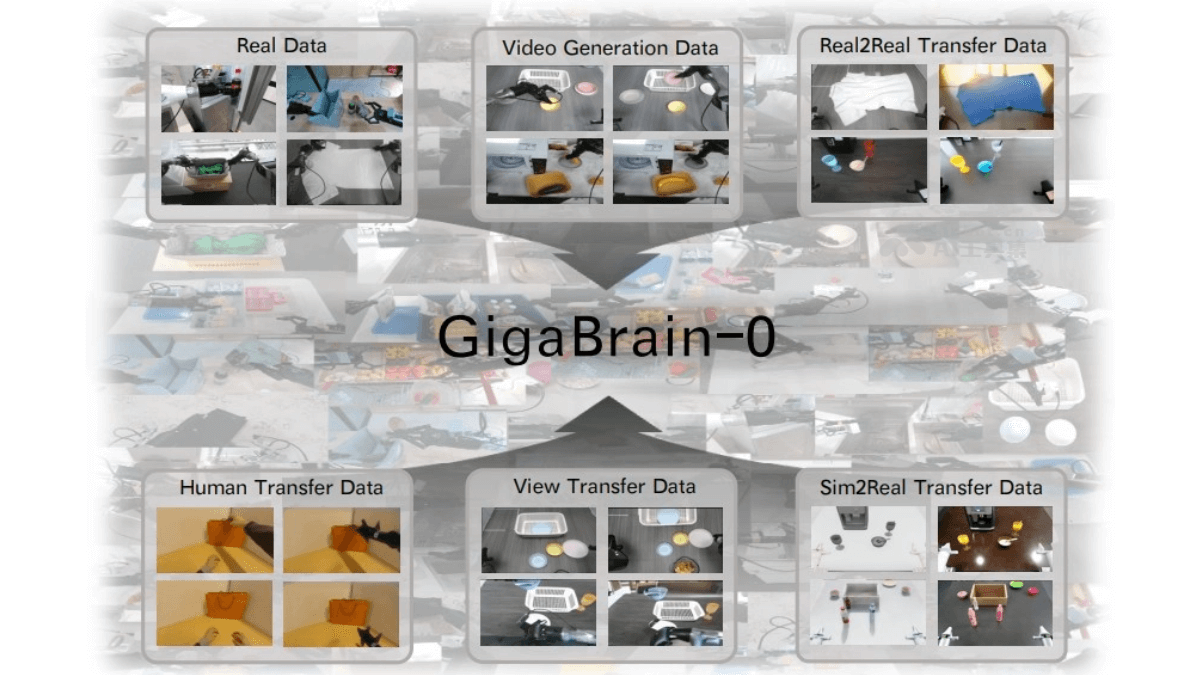
Main Features of GigaBrain-0
-
Data generation and reduced dependency: Utilizes a world model to generate diverse data, such as video generation, Real2Real transfer, human transfer, etc., reducing reliance on real robot data and improving model generalization.
-
RGB-D input and spatial perception: Enhances spatial perception through RGB-D input, enabling the model to more accurately perceive the 3D positions and spatial layout of objects, improving manipulation precision.
-
Embodied Chain-of-Thought supervision and reasoning ability: Generates intermediate reasoning steps during training, such as manipulation trajectories, sub-goal planning, etc., simulating the human thought process and enhancing reasoning ability for complex tasks.
-
Task success rate and generalization ability: Demonstrates high success rates and strong generalization ability across various tasks, such as clothes folding, table clearing, box carrying, etc., and can adapt to scenarios with changes in appearance, object placement positions, and camera viewpoints.
-
Lightweight version and edge platform adaptation: Introduces the GigaBrain-0-Small lightweight version, specifically designed for edge platforms such as NVIDIA Jetson AGX Orin, enabling efficient inference and meeting practical deployment needs.
Technical Principles of GigaBrain-0
-
World model driven: Generates large-scale diverse data through a world model, reducing reliance on real robot data and improving model generalization.
-
RGB-D input modeling: Utilizes RGB-D input to enhance spatial perception, enabling the model to more accurately perceive the 3D positions and spatial layout of objects.
-
Embodied Chain-of-Thought supervision: Generates intermediate reasoning steps during training, such as manipulation trajectories, sub-goal planning, etc., simulating the human thought process and enhancing reasoning ability for complex tasks.
-
Knowledge isolation: Adopts knowledge isolation techniques during training to prevent the optimization processes of action prediction and Embodied Chain-of-Thought generation from interfering with each other, improving model stability and performance.
-
Combination of reinforcement learning and world models: In the future, world models can be integrated as interactive policy environments for reinforcement learning, reducing the need for real-world trial and error and improving learning efficiency.
-
World model as a policy generator: World models are expected to learn general representations of physical dynamics and task structures, evolving into "active policy generators" that directly propose feasible action sequences or sub-goals.
-
Closed-loop self-improvement cycle: Through a closed-loop self-improvement cycle between the VLA policy and the world model, real-world trajectories continuously optimize the world model, and the world model in turn generates higher-quality training data, driving the development of autonomous, lifelong-learning robotic systems.
GigaBrain-0 project links
- Project website:https://gigabrain0.github.io/
- Github repository:https://github.com/open-gigaai/giga-brain-0
- HuggingFace model hub:https://huggingface.co/open-gigaai
- arXiv technical paper:https://arxiv.org/pdf/2510.19430
Application scenarios of GigaBrain-0
-
Dexterous manipulation tasks: such as folding clothes, preparing tissues, etc. GigaBrain-0 can complete the operations precisely and shows good generalization ability across clothing of different textures and colors.
-
Long-horizon tasks: such as clearing the dining table, making juice, etc. The model can perform fine-grained, chronologically ordered planning to complete complex long-horizon tasks.
-
Mobile manipulation tasks: such as carrying boxes, carrying laundry baskets, etc. GigaBrain-0 can combine global navigation with local manipulation policies to achieve seamless transitions between movement and interaction.
-
Edge platform deployment: The lightweight version GigaBrain-0-Small is designed for edge platforms such as NVIDIA Jetson AGX Orin, meeting practical deployment needs and enabling efficient operation on resource-constrained devices.