
What is Genie Envisioner
Genie Envisioner is the first robot world model open-source platform launched by AgiBot. The platform integrates policy learning, evaluation, and simulation functions through a unified video generation framework. Core components include GE-Base (a large-scale instruction-conditioned video diffusion model), GE-Act (an action trajectory decoder), GE-Sim (a neural simulator), and EWMBench (a standardized benchmark suite). The platform supports policy generalization across robot embodiments, helping robots achieve precise operations in complex tasks, advancing the development of embodied intelligence, and providing strong support for robotics research and applications.
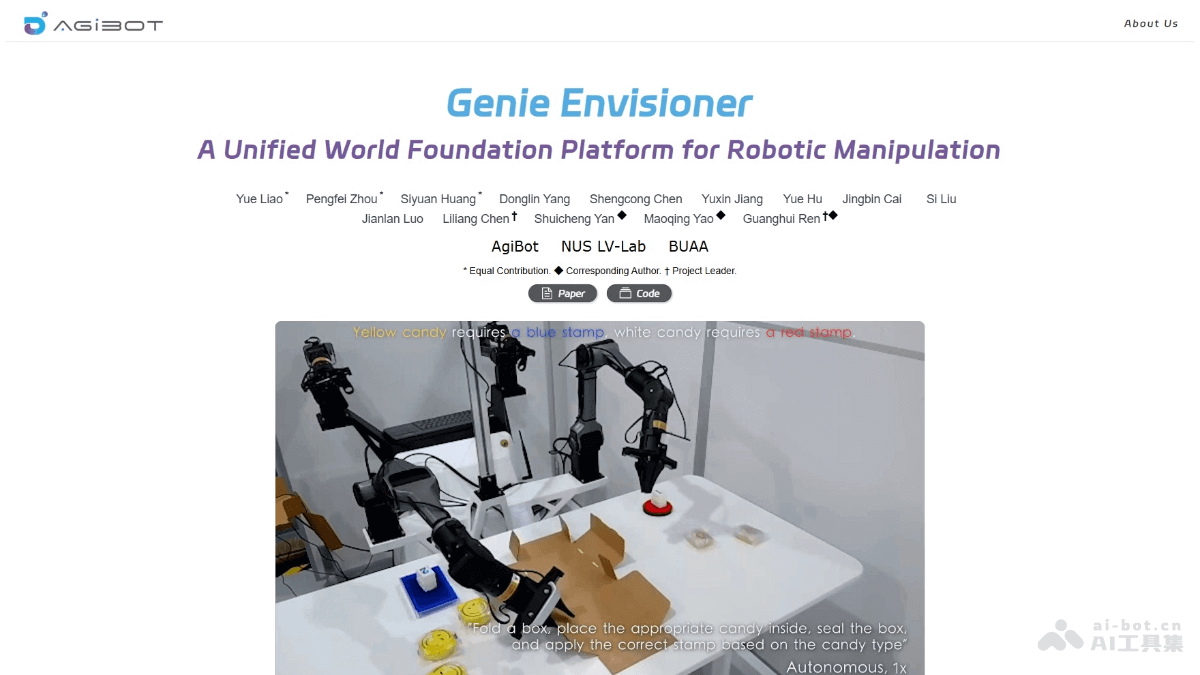
Genie Envisioner's Main Features
- Policy Learning: Based on GE-Base, it captures the dynamics of robot-environment interaction and generates policies for action decision-making.
- Action Generation: Maps representations in latent space to executable action trajectories, supporting multiple robot embodiments.
- Simulation Support: Provides a high-fidelity simulation environment for closed-loop testing and optimization of policies.
- Performance Evaluation: Provides standardized benchmarks to measure visual fidelity, physical consistency, and instruction-action alignment.
Genie Envisioner's Technical Principles
- GE-Base: GE-Base is a large-scale instruction-conditioned video diffusion model that can capture the spatial, temporal, and semantic dynamics of robot interaction. It represents complex robot interactions in a structured latent space for subsequent processing.
- GE-Act: GE-Act uses a lightweight flow matching decoder to map representations in latent space to executable action trajectories. It supports policy transfer across multiple robot embodiments with only a small amount of supervision signal.
- GE-Sim: GE-Sim is an action-conditioned neural simulator used to generate high-fidelity rollouts. It supports policy development and optimization in virtual environments, reducing the need for physical experiments.
- EWMBench: EWMBench provides a standardized test suite used to measure a model's visual fidelity, physical consistency, and degree of instruction-action alignment. It helps researchers and developers evaluate and optimize model performance.
Genie Envisioner's Project Address
- Project Website:https://genie-envisioner.github.io/
- GitHub Repository:https://github.com/AgibotTech/Genie-Envisioner
- arXiv Technical Paper:https://arxiv.org/pdf/2508.05635
Genie Envisioner's Application Scenarios
- Industrial Automation: On factory production lines, it helps robots complete complex assembly, handling, and quality inspection tasks more precisely, improving production efficiency and product quality.
- Logistics and Warehousing: Used for goods sorting and handling in logistics centers, robots quickly identify and process items of different shapes and sizes according to instructions, optimizing logistics processes.
- Service Robots: In restaurants, hotels, or home environments, it gives robots the ability to understand and execute human instructions, providing more intelligent services such as food delivery, cleaning, and item delivery.
- Medical Assistance: In medical scenarios, robots perform surgical assistance, rehabilitation training, or medication delivery, improving the precision and efficiency of medical services.
- Education and Research: Provides universities and research institutions with a powerful experimental platform, supporting research in robot learning, artificial intelligence, and embodied intelligence, and advancing the development of related technologies.