
What is ERA-42
ERA-42 is an end-to-end native robot large model launched by Beijing Star Dynamics. Combined with the self-developed five-fingered dexterous hand Star Dynamics XHAND1, it can complete more than 100 complex dexterous manipulation tasks. ERA-42 requires no pre-programming and has the ability to quickly learn new skills, and can learn a new task within 2 hours using a small amount of data. As the industry's first five-fingered dexterous hand embodied large model, ERA-42 demonstrates powerful cross-modal capabilities, adaptability, and generalization ability, leading embodied large models into the era of general dexterous manipulation and heralding the vision of robots serving all industries and entering thousands of households.
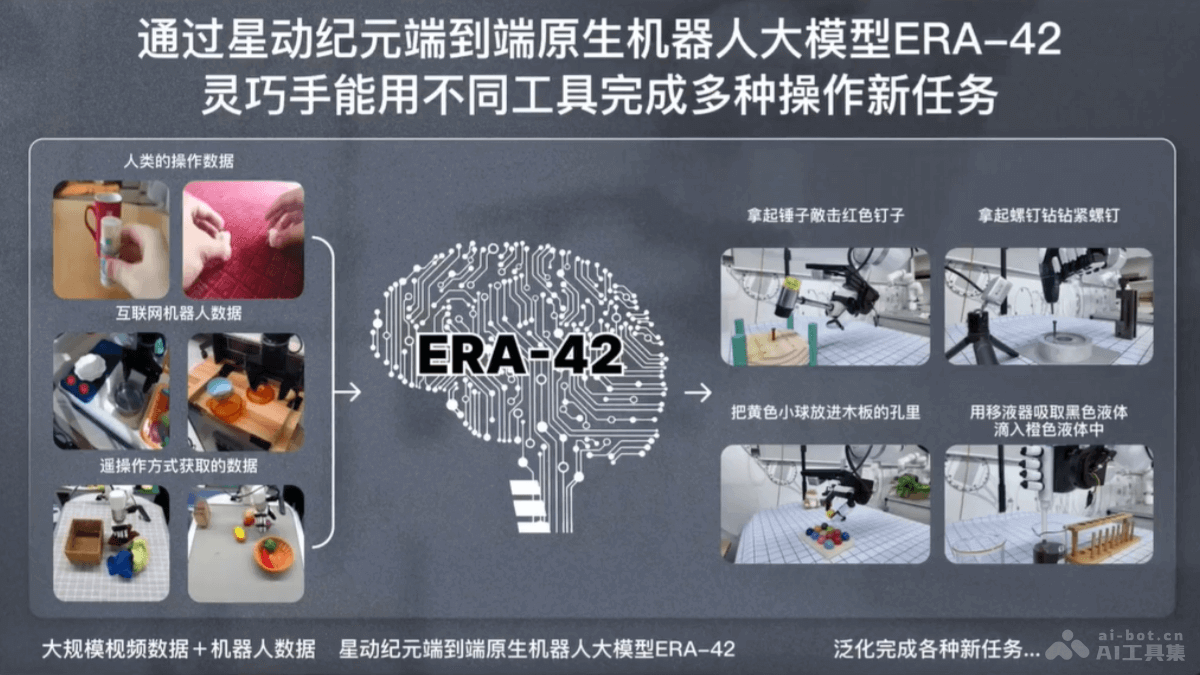
Main functions of ERA-42
- Dexterous manipulation capability: Combined with the Star Dynamics XHAND1 five-fingered dexterous hand, it can perform more than 100 complex dexterous manipulation tasks, such as using tools and grasping objects.
- Rapid learning of new skills: Quickly learn and execute new tasks without pre-programming, and can learn a new task through a small amount of data in less than 2 hours.
- Cross-modal capability: The model integrates full-modal information such as vision, language, touch, and body posture to achieve generalization ability across different tasks and environments.
- End-to-end execution: The entire process from receiving full-modal data to generating the final output (such as decisions, actions, etc.) is completed based on a concise neural network pipeline, without the need for manually designed features, pre-programming, or intervention in processing steps.
- Understanding and prediction of the physical world: After integrating the world model, it has the ability to understand the physical world and predict future action trajectories.
Technical principles of ERA-42
- Unified model generalization: Based on building a unified native model and integrating multiple modal information, it achieves generalization ability across different tasks and environments.
- End-to-end learning: It adopts an end-to-end learning method, directly from full-modal input to final output, without intermediate human intervention, improving flexibility and development efficiency.
- Data-driven adaptation and generalization: It learns strategies based on large-scale video data, uses the results after actions to grasp causal relationships, and achieves complete generalization.
- World model integration: The world model is integrated into the native robot large model, so that it not only has action capabilities but also has the ability to understand the physical world.
- Joint learning of prediction and action: Through the joint denoising process, ERA-42 can learn how to use actions to improve predictions, enhancing the efficiency and accuracy of task execution.
Application scenarios of ERA-42
- Industrial automation: Used in automated production lines to perform complex assembly, inspection, and maintenance tasks, improving production efficiency and quality.
- Medical assistance: In the medical field, it assists in fine surgical operations, or performs sample processing and experimental operations in laboratories.
- Home services: As a home service robot, it completes household tasks such as cleaning, cooking, and organizing items, improving the quality of life.
- Disaster rescue: It performs search and rescue tasks at disaster sites, especially in environments that are difficult for humans to reach or dangerous.
- Logistics and distribution: Used in warehouse management and goods sorting, improving logistics efficiency and reducing labor costs.