
What Is DynaMem
DynaMem is a dynamic spatial semantic memory system introduced by New York University and Hello Robot, designed for mobile manipulation in open worlds. It is based on maintaining a feature point cloud as the robot's memory, handling dynamic changes in the environment, such as the addition and removal of objects. When new RGBD observations are received, DynaMem updates the memory, adding new objects and removing points that no longer exist. DynaMem locates objects based on text queries and navigates to the target object when necessary. DynaMem performs excellently in handling dynamic objects, achieving a success rate of 70%, significantly higher than traditional systems.
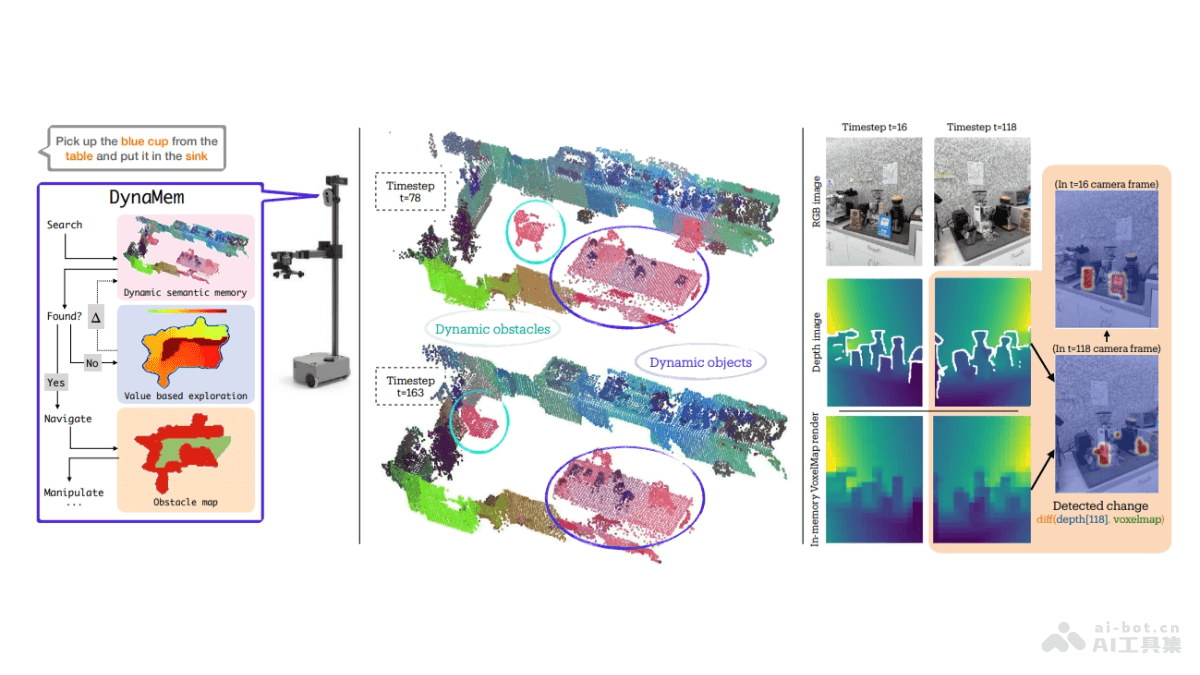
DynaMem's Main Features
- Dynamic Spatial Semantic Memory: Maintains a dynamically updated feature point cloud as the robot's memory system, adapting to changes in the environment.
- Environment Perception and Update: When the robot receives new RGBD (red, green, blue, depth) observations, DynaMem adds the newly observed objects to the memory and removes points that no longer exist.
- Text Query Localization: Locates objects of interest in the environment based on text queries, using the point found to be most similar to the text query and the image in which it was last observed.
- Navigation and Interaction: If the text is successfully localized in the environment, navigate the robot to the target object; if the text cannot be localized in the environment, explore the environment to find the target.
- Dynamic Object Handling: DynaMem excels at handling dynamic objects in the environment, with only very few trials failing because it could not navigate to a dynamic object.
- Value Map Exploration: Projects the robot's memory onto a value map to guide the robot in exploring the environment.
DynaMem's Technical Principles
- Feature Point Cloud Maintenance: Maintains a feature point cloud as the robot's memory, and the point cloud updates dynamically as the environment changes.
- RGBD Observation Fusion: When the robot receives new RGBD observations, DynaMem fuses the observations into the existing memory, reflecting the latest state of the environment.
- Text Query Matching: Based on advanced vision-language models (VLMs) and multimodal large language models (mLLMs), understands and matches text queries to locate objects in memory.
- Similarity Evaluation: Evaluates the similarity between feature points in the point cloud and the text query to determine the object's location.
- Environment Navigation: If the text query successfully localizes an object in the environment, guide the robot to navigate to that object; if it cannot be localized, use the value map to guide the robot in exploring the environment.
DynaMem's Project Address
- Project Website:dynamem.github.io
- arXiv Technical Paper:https://arxiv.org/pdf/2411.04999
DynaMem's Application Scenarios
- Home Automation: In home environments, helps service robots recognize, locate, and manipulate furniture, appliances, or other household items.
- Industrial Automation: In manufacturing and logistics, assists robots in sorting, handling, and assembling items on production lines.
- Warehouse Management: In warehouse environments, helps robots with inventory management, including locating, picking, and handling goods, especially when goods frequently enter and leave.
- Disaster Rescue: In disaster rescue scenarios, helps robots navigate through ruins and search for survivors or important items.
- Agricultural Automation: In the field of agriculture, assist robots in crop monitoring, harvesting, and handling.