
What is 10Kh RealOmni-Open
10Kh RealOmni-Open is an open-source embodied intelligence dataset from the Gen Robot.AI team, and is one of the largest open-source datasets in the industry. It contains over 10,000 hours of data, 1 million+ task clips, and a total storage volume of 95TB. The dataset focuses on 10 common household tasks, with over 10,000 clips for each skill, ensuring skill depth. Data was collected from 3,000 real homes, with high image clarity (1600×1296 pixels, 30fps), trajectory accuracy at the sub-centimeter level, and includes gripper opening and closing angle and displacement information.
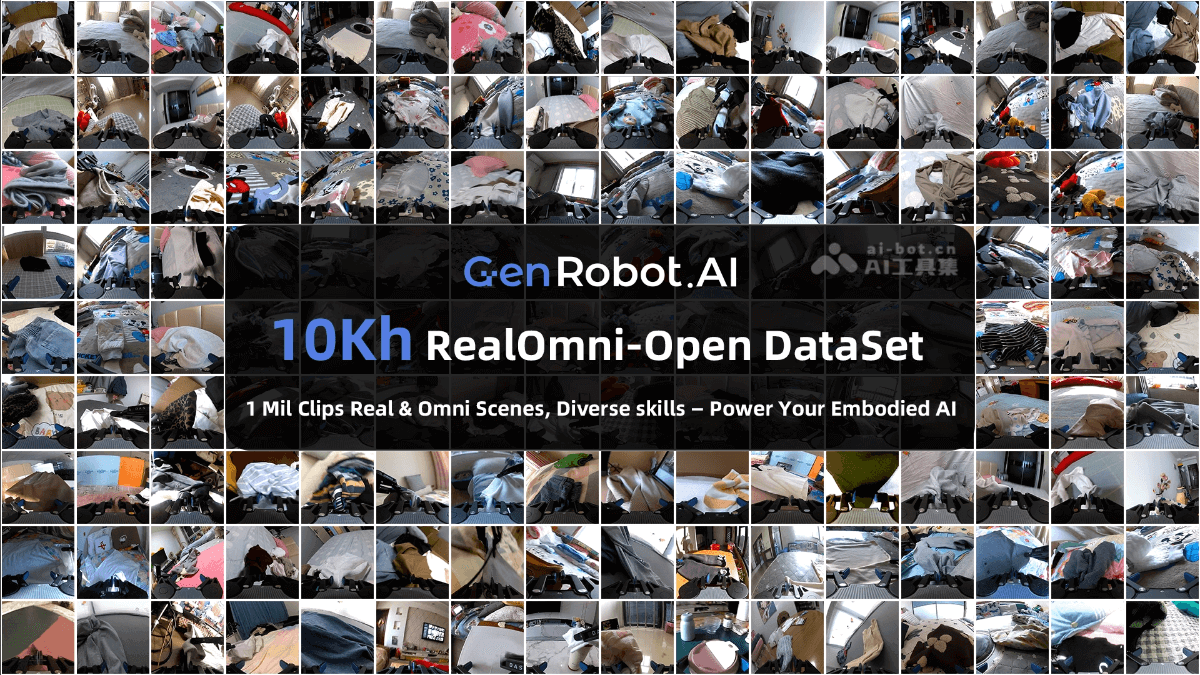
Main features of 10Kh RealOmni-Open
-
Large-scale data coverage: Contains over 10,000 hours of data and 1 million+ task clips, with a total storage volume of 95TB, making it a leading open-source embodied intelligence dataset in the industry.
-
Focus on core skills: The dataset focuses on 10 common household tasks, with each skill having over 10,000 clips, ensuring deep skill coverage.
-
High-quality data collection: High image clarity (1600×1296 pixels, 30fps), trajectory accuracy at the sub-centimeter level, and it also includes gripper opening and closing angle and displacement information.
-
Real-world scene generalization: Data was collected from 3,000 real homes, 99.2% are bimanual long-horizon tasks, the average clip length is 1 minute 37 seconds, recording the complete action process, suitable for applications in a variety of real-world scenarios.
-
Efficient data storage: Stored in MCAP format, the first phase of data totals 950 hours, including 39,761 task clips, making it convenient for developers to access on demand.
-
Usability support: Provides a web tool and an open-source toolkit, supports both Chinese and English, follows the CC-BY-SA-4.0 license, allows commercial use, and also provides detailed usage guidance.
-
Continuous updates and feedback: The dataset is still being continuously updated to realize the goal of "digitizing all human skills", and user feedback and suggestions are welcome.
Data characteristics of 10Kh RealOmni-Open
-
Massive scale: Contains over 10,000 hours of data, 1 million+ task clips, and a total storage volume of 95TB, making it one of the largest open-source embodied intelligence datasets in the industry.
-
Skill depth: Focuses on 10 common household tasks, with each skill having over 10,000 clips, ensuring depth and richness of skills.
-
High-quality visuals: High image clarity, with a resolution of 1600×1296 and a frame rate of 30fps, capable of recording the environment and operation details in all directions.
-
High-precision trajectories: Trajectory accuracy reaches the sub-centimeter level, achieved through high-precision IMU hardware and cloud reconstruction technology, suitable for robot learning.
-
Multimodal data: Includes multiple modalities such as visual and auditory data, and also records gripper opening and closing angle and displacement information.
-
Real-world scene collection: Data comes from 3,000 real homes, with strong generalization ability for scenes and targets, natural operations, and it avoids the problems of single scenes and repetitive actions.
-
Long-horizon task recording: 99.2% are bimanual long-horizon tasks, with an average clip length of 1 minute 37 seconds, recording the complete action process, suitable for learning action logic and causality.
-
Efficient storage format: Stored in MCAP format, the first phase of data totals 950 hours and contains 39,761 task clips, making it easy for developers to call on demand.
-
Usability support: Provides a web tool and an open-source toolkit, supports both Chinese and English, follows the CC-BY-SA-4.0 license, allows commercial use, and provides detailed usage guidance.
Project address of 10Kh RealOmni-Open
- Hugging Face model repository:https://huggingface.co/datasets/genrobot2025/10Kh-RealOmin-OpenData
Application scenarios of 10Kh RealOmni-Open
-
Home service robot training: Provides rich task data for home service robots, helping robots learn and optimize daily household skills, such as organizing items and cleaning tabletops.
-
Reinforcement learning research: Provides large-scale real-world environment data for reinforcement learning algorithms, supports algorithm training and optimization in complex tasks, and enhances robots' decision-making capabilities.
-
Research on robot vision and action coordination: Through multimodal data, supports research on robot vision and action coordination, helping robots better understand and execute tasks.
-
Research on skill transfer and generalization: Based on diverse home scenarios and tasks, supports research on robot skill transfer and generalization, enabling adaptation to different environments and task requirements.
-
Human-robot interaction optimization: By recording real human-robot interaction data, helps optimize the way robots collaborate with humans and improves the naturalness and efficiency of interaction.
-
Embodied intelligence model development: Provides high-quality data support for developing embodied intelligence models, helping models be applied and deployed in real-world scenarios.